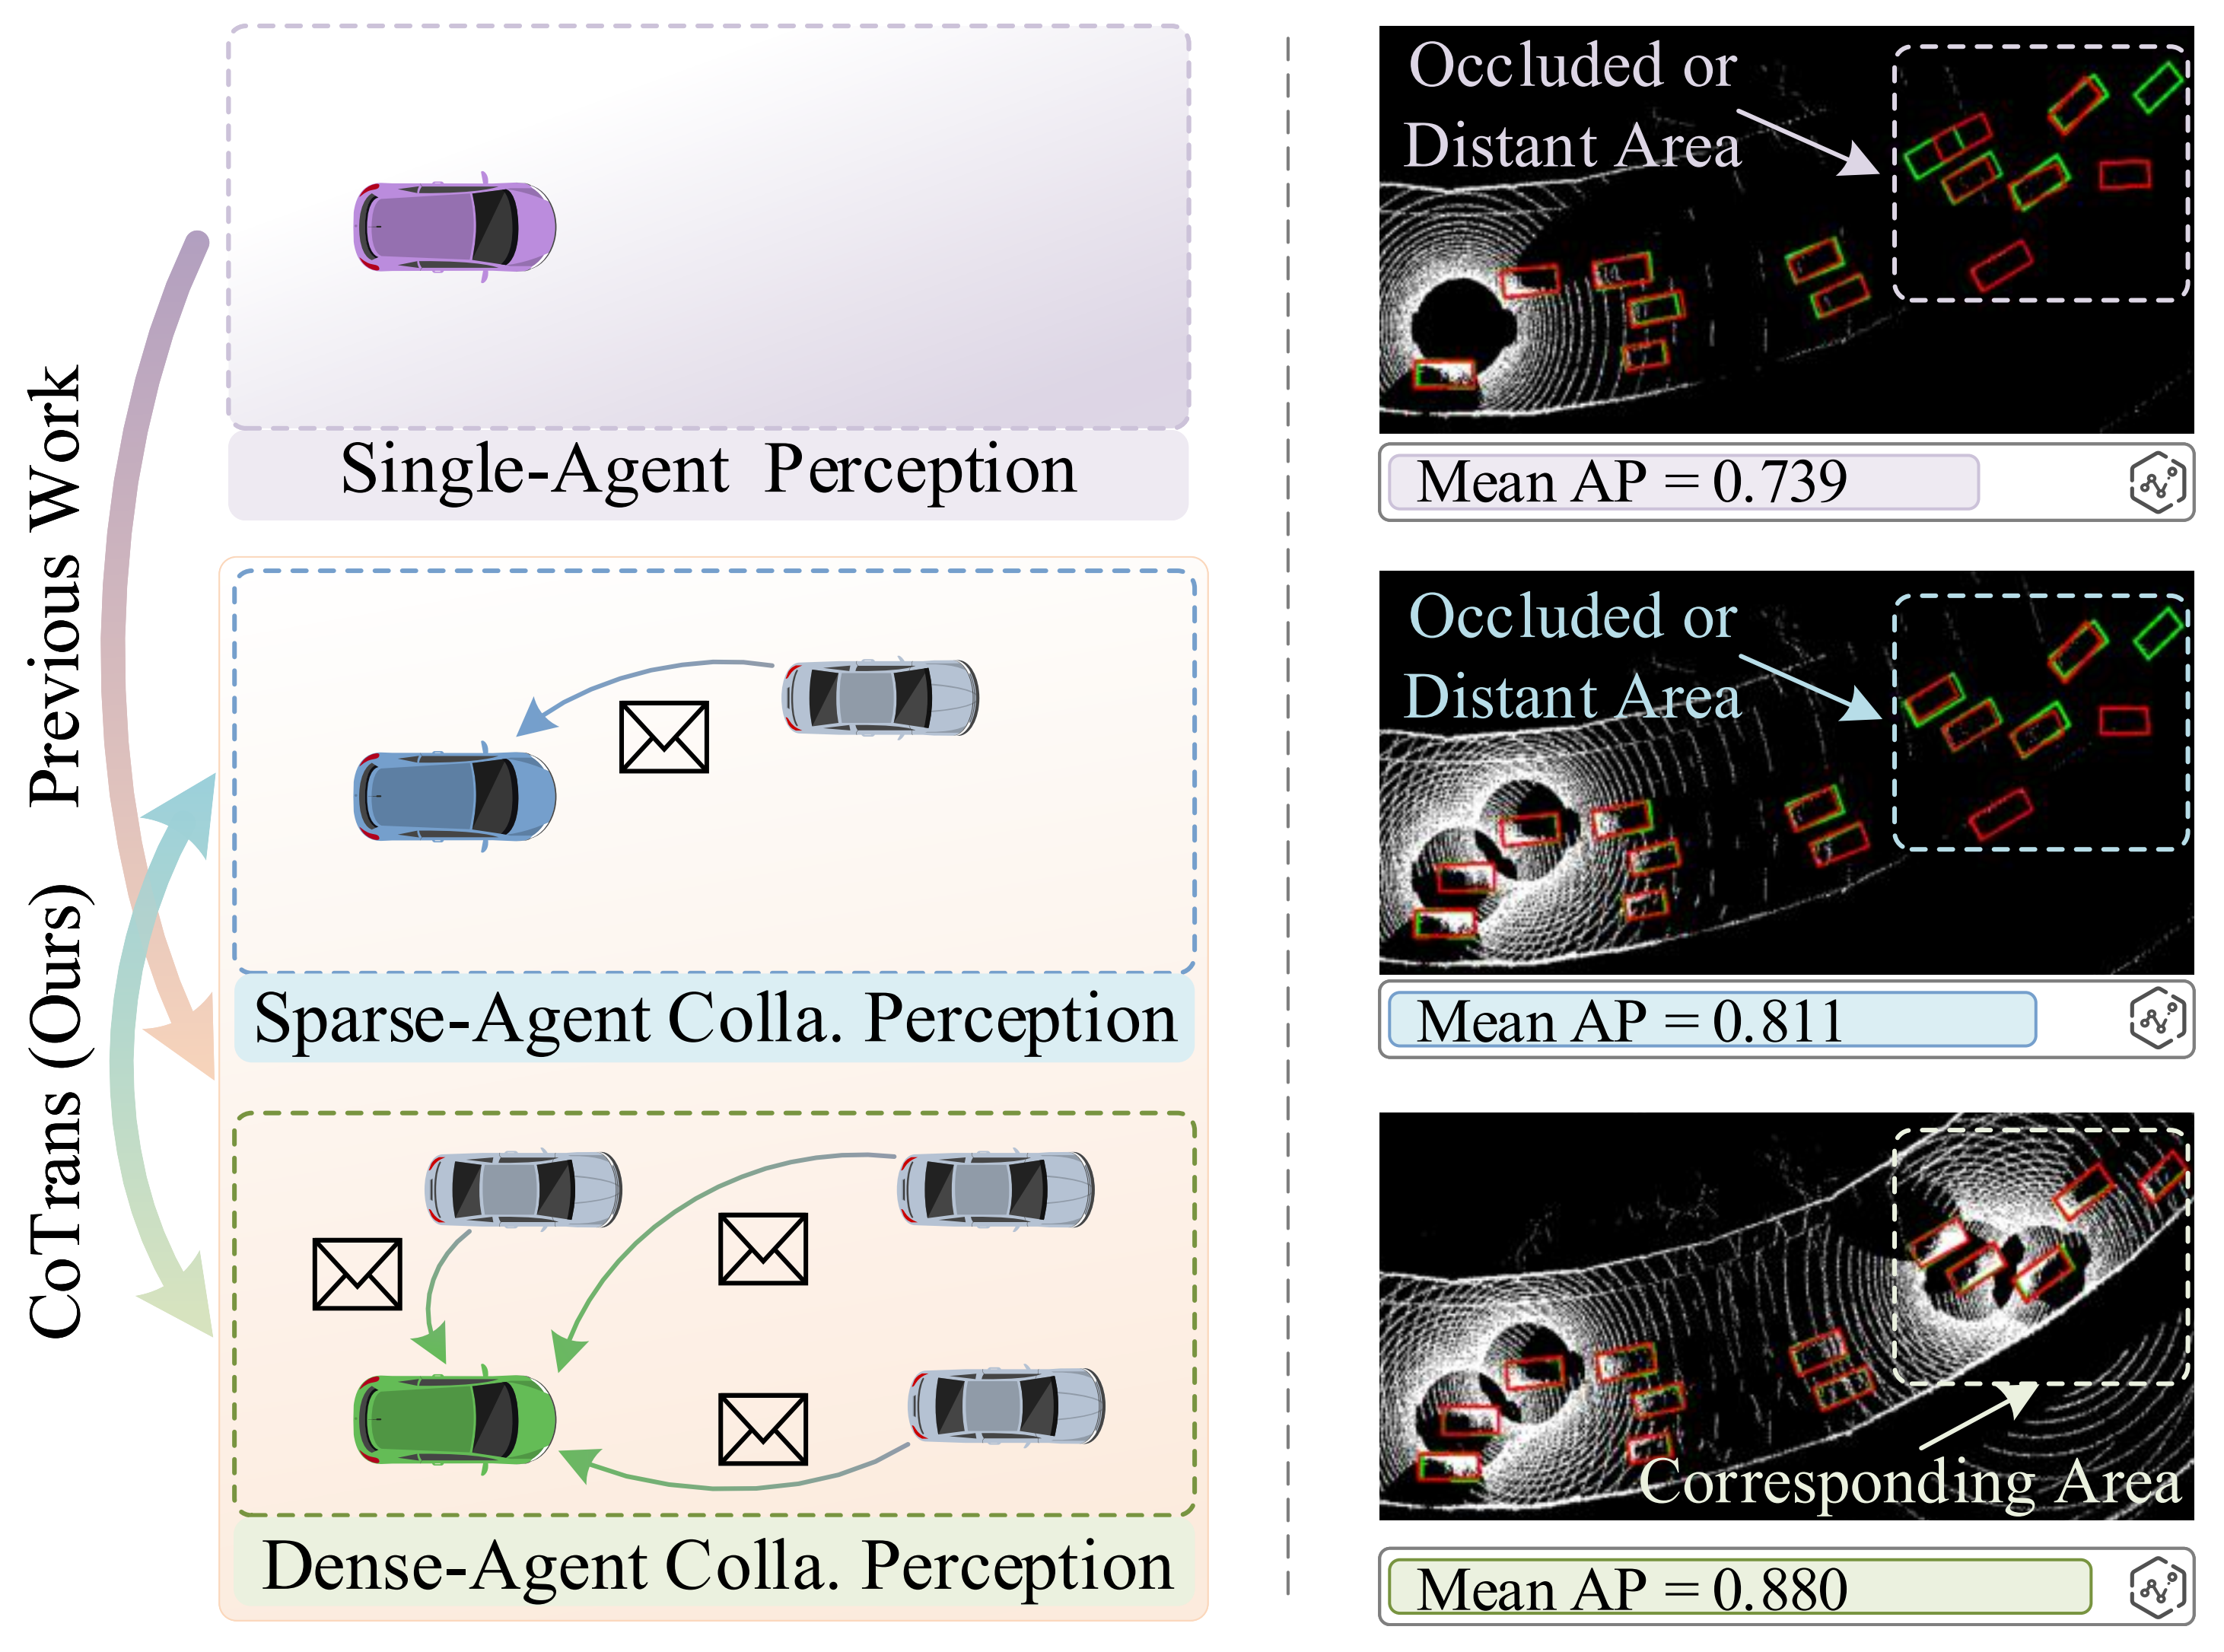
Collaborative perception is a powerful paradigm that addresses the limitations of single-agent perception caused by occlusion and distance. However, in practice, sparse-agent collaborative perception (SCP) faces similar vulnerabilities to single-agent perception, leading to significant performance degradation compared to dense-agent collaborative perception (DCP). In this paper, we investigate the negative impact of SCP and propose a unified framework, CoTrans, to bridge the SCP-DCP gap for existing collaborative perception methods. This framework relies on a conceptually simple yet efficient collaboration translation, which simulates the gap in a learnable manner. Furthermore, in CoTrans, a drop-agent strategy is introduced to support the learning process without any communication burden, and a lightweight injection network equipped with localization and injection capabilities is proposed to fuse collaboration translation and SCP features. To the best of our knowledge, this is the first unified framework designed to enhance SCP. Extensive experiments across five large-scale collaborative perception datasets demonstrate that CoTrans consistently enhances existing collaborative systems in SCP scenarios, while introducing only 1ms inference latency. In particular, it achieves a 6.6\% AP gain for AttFuse on the real-world DAIR-V2X dataset under sparse-agent conditions.
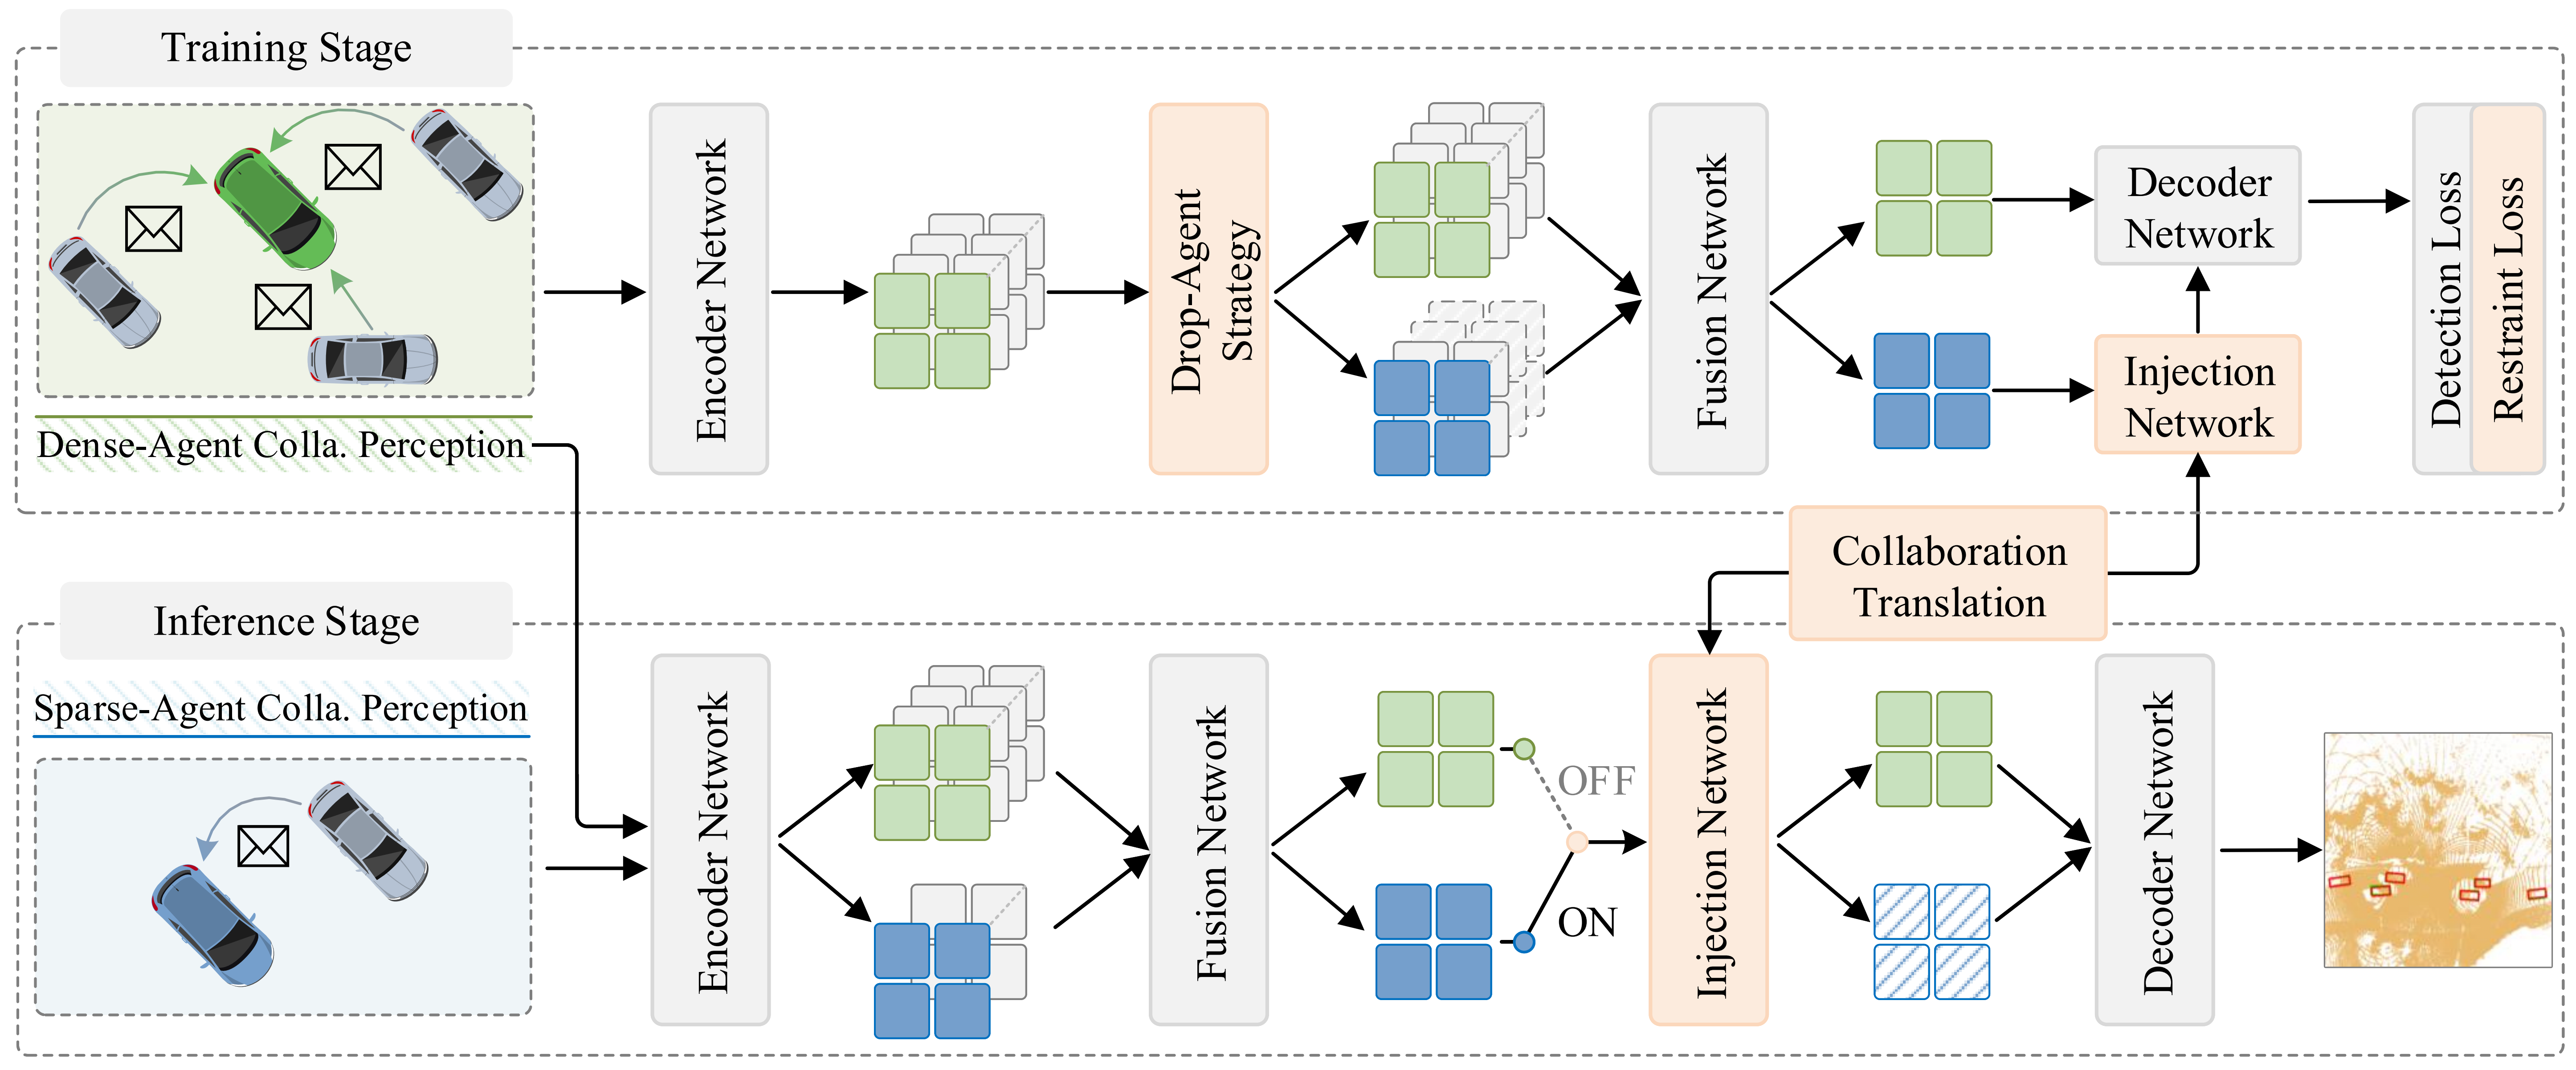
CoTrans is a novel general extension for enhancing sparse-agent collaborative perception (SCP). Core innovations include: (1) A global collaboration translation that explicitly models disparities between SCP and dense-agent collaborative perception (DCP); (2) A lightweight injection network that adaptively personalizes and integrates the translation to refine SCP features; and (3) A drop-agent strategy enabling training of collaboration translation by generating simulated SCP scenarios from real DCP data without communication overhead.
3D object detection visualization across collaborative perception models. Green and red boxes are ground-truth and detection, respectively. Among the six models evaluated, CoTrans significantly enhances detection precision.
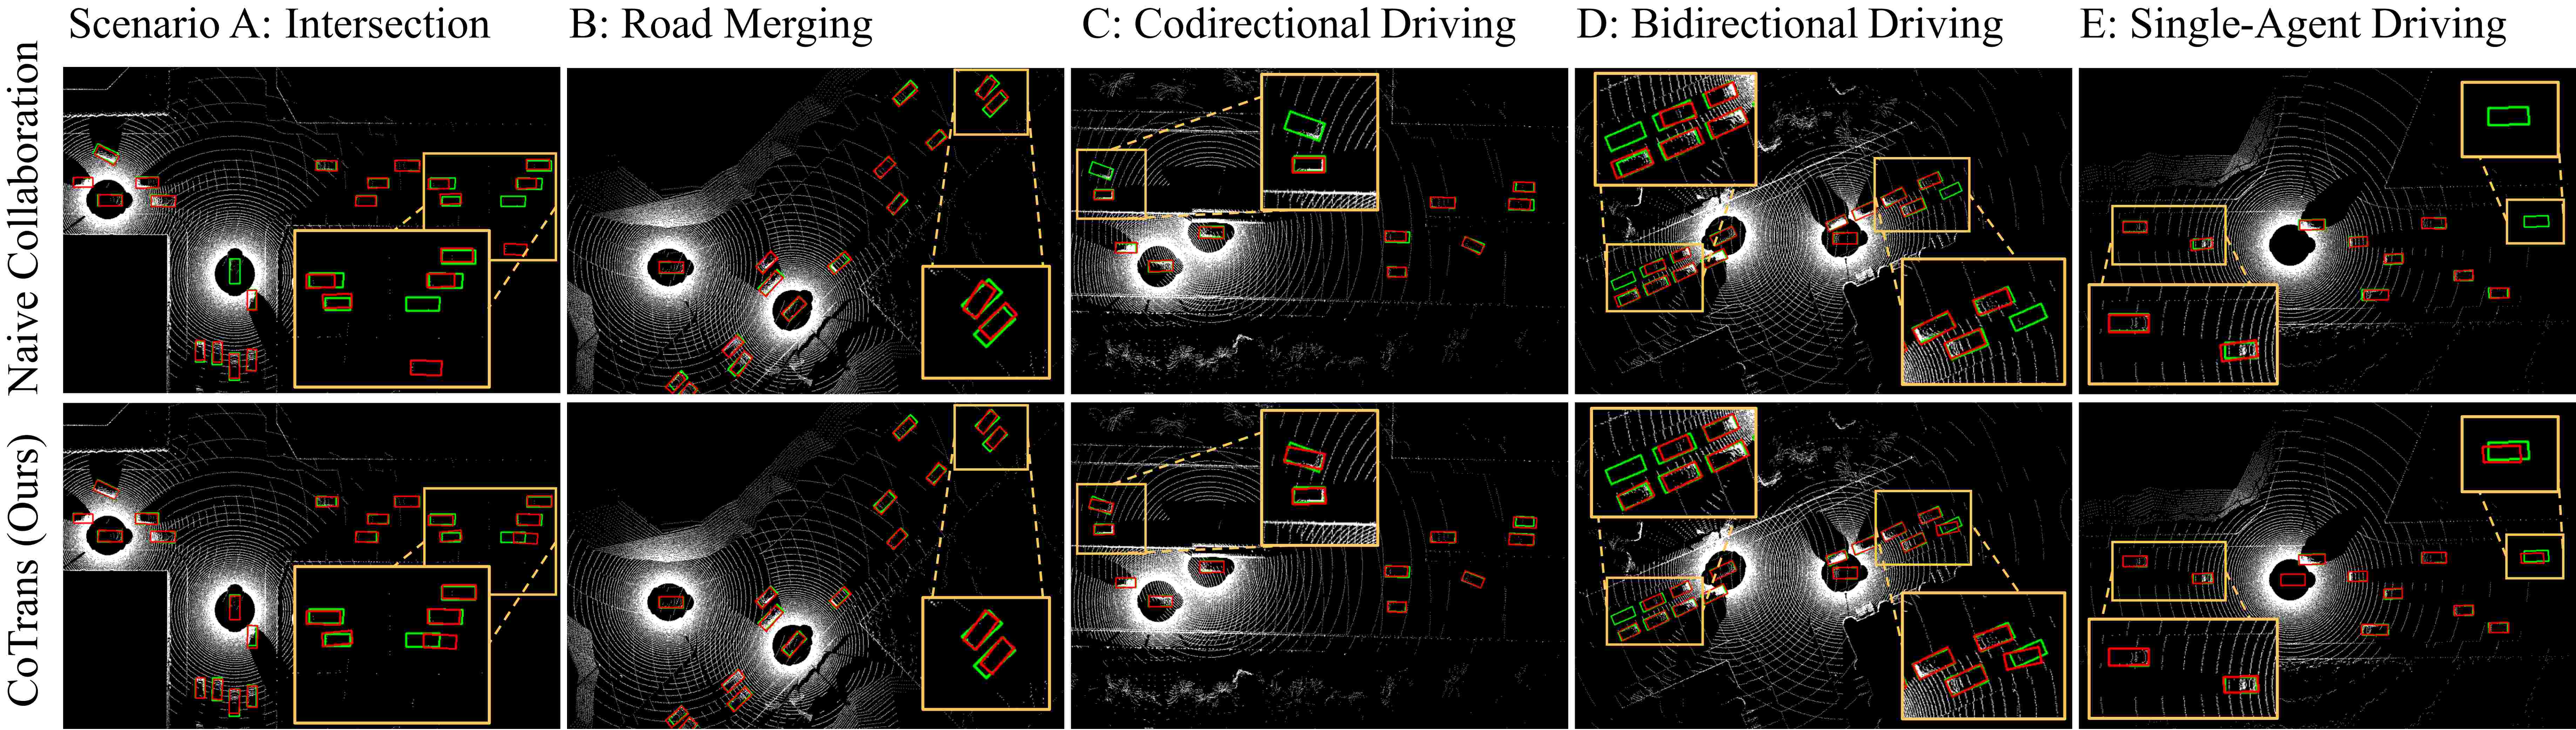
3D object detection visualization in challenging driving scenarios. Green and red boxes denote ground-truth and detection, respectively. CoTrans achieves superior performance across diverse environments compared to naive collaboration.
@article{Wei2025CoTrans,
      author    = {Quanmin Wei, Penglin Dai, Ke Li, Wei Li, Xiao Wu, Zhaofei Yu},
      title     = {CoTrans: A Unified Framework for Enhancing Sparse-Agent Collaborative Perception},
      year      = {2025}
  }